
Haoyang Wu (吴浩洋)
Hi! I’m Haoyang (William) Wu, a junior undergraduate student majoring in Computer Science at the University of Michigan. I am also pursuing a dual degree in Electrical and Computer Engineering at Shanghai Jiao Tong University, with an expected graduation in 2027.
I am broadly interested in embodied AI, robot learning, and vision-language models. My research goal is to develop scalable methods that enable robots to use high-level semantic understanding for precise, adaptive manipulation in unseen environments.
I am currently a research intern at Princeton University, working with Prof. Zhuang Liu and Prof. Danqi Chen. I also work as a research intern in the ARM Lab directed by Prof. Dmitry Berenson. Previously at SJTU, I was deeply engaged in surgical robotics research at the SIRIUS Lab, mentored by Prof. Yutong Ban.
You can find my resume (updated 09/21/2025) here
I’m actively searching for PhD opportunities in Robotics starting Fall 2027
Publications
Topology-Informed Visual Prompting For Vision Language Action Policies
In submission to ICRA, 2027
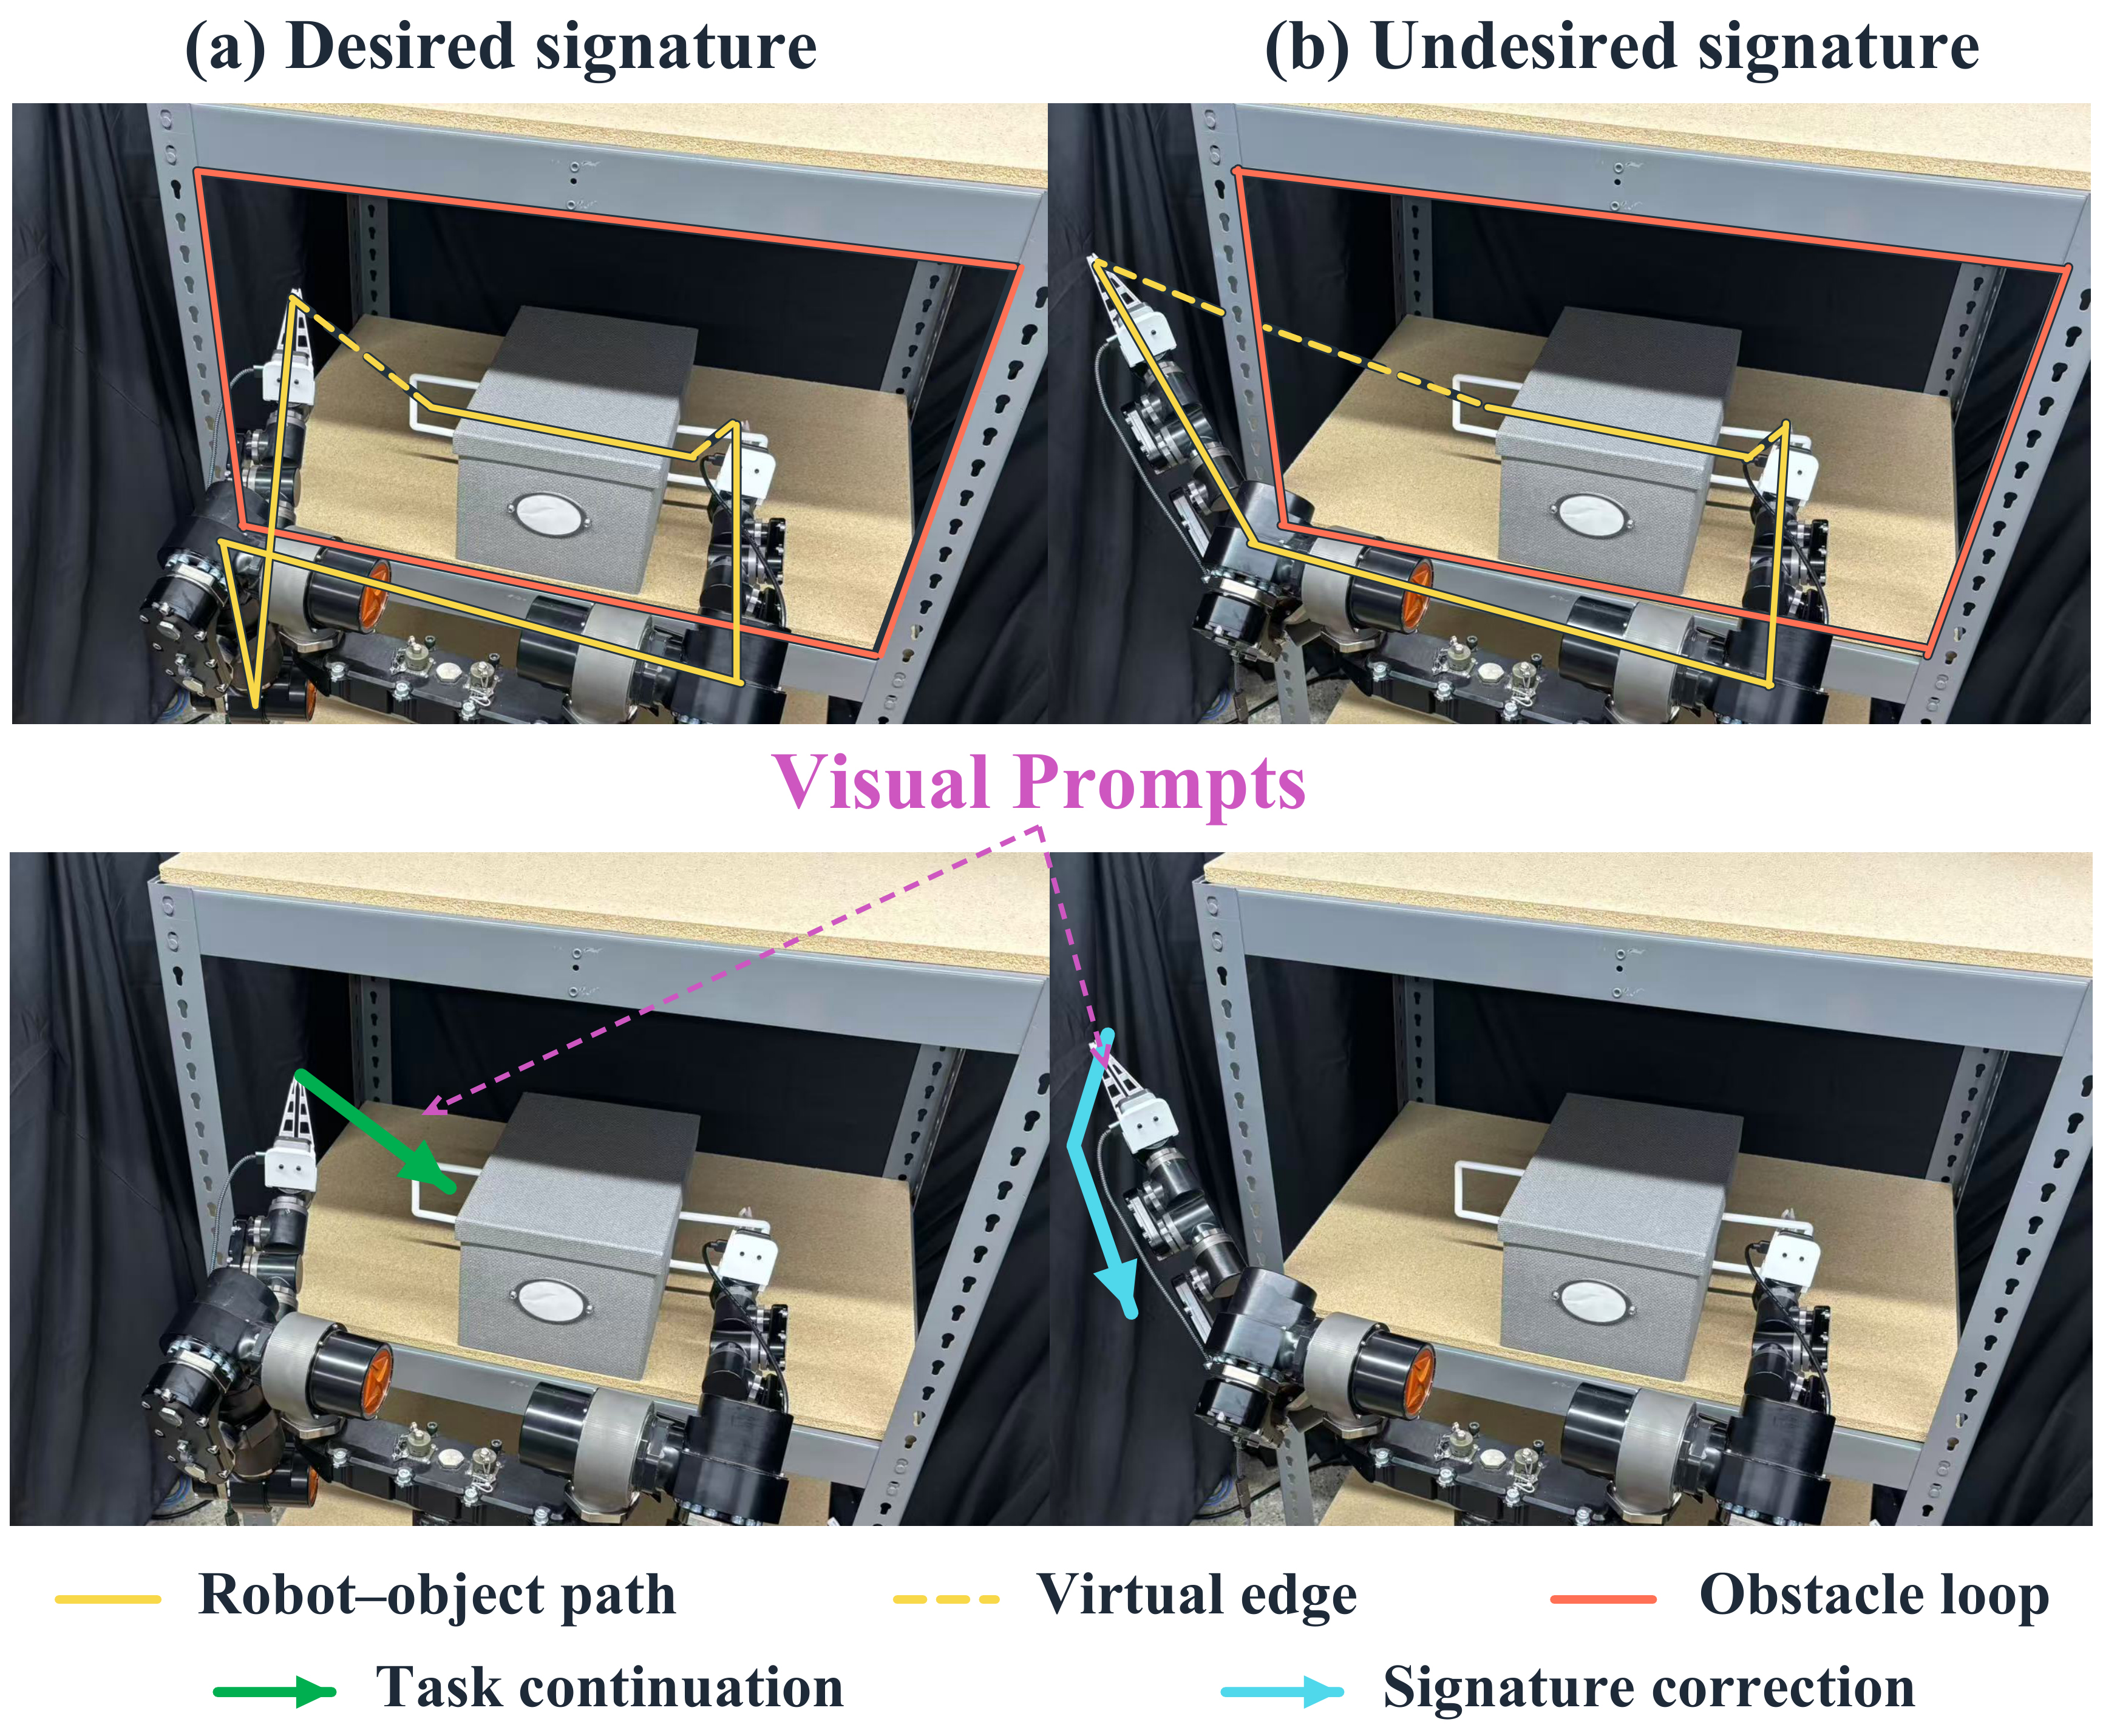
Vision-language-action policies often struggle to manipulate objects around complex obstacles. We use simulated planning and topological reasoning to generate additional training trajectories, then visually prompt the policy with predicted robot waypoints during deployment. Our method improves performance across simulated and real-world tasks, increasing hardware success by 40% over the strongest baseline.
Haoyang Wu, Abhinav Kumar, Dmitry Berenson
Download Paper
Vero: An Open RL Recipe for General Visual Reasoning
European Conference on Computer Vision (ECCV), 2026
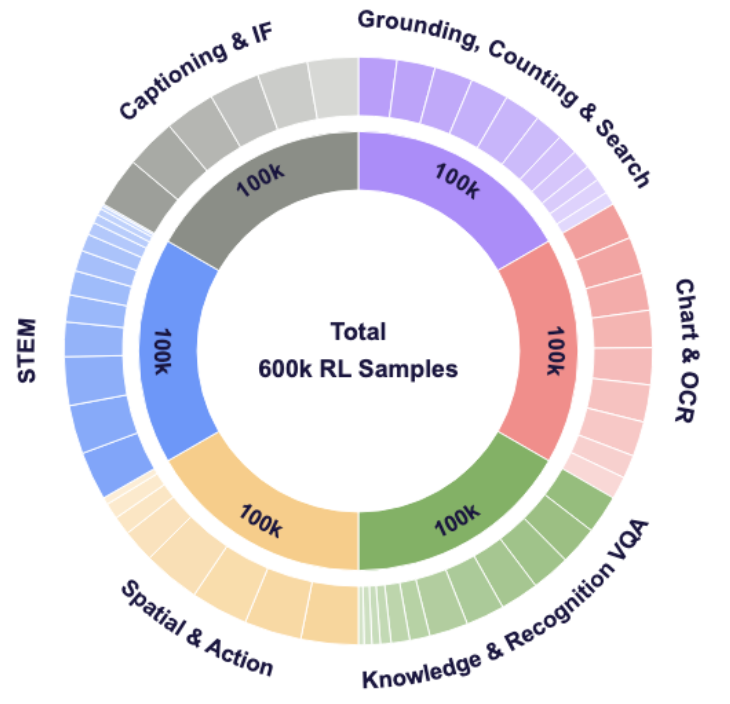
We introduce Vero, a family of fully open vision-language models (VLMs) designed for general visual reasoning across diverse domains such as charts, science, and spatial understanding. By scaling reinforcement learning (RL) data with the 600K-sample Vero-600K dataset and task-routed rewards, Vero achieves state-of-the-art performance on 30 challenging benchmarks, demonstrating that broad data coverage is the key driver of strong RL scaling. All data, code, and models are publicly released.
Gabriel Sarch, Linrong Cai, Qunzhong Wang, Haoyang Wu, Danqi Chen, Zhuang Liu
Download Paper | Download Slides
Holistic Surgical Phase Recognition with Hierarchical Input Dependent State Space Models
In submission to IEEE TMI, 2025
We propose a hierarchical input-dependent state space model that leverages the linear scalability of SSMs for decision-making over full-length videos. Our framework couples a temporally consistent visual encoder with an SSM head to propagate temporal information. The temporal module consists of two components: a local aggregation block for fine-grained dynamics and a global relation block for long-range dependencies.
Haoyang Wu, Tsun-Hsuan Wang, Mathias Lechner, Ramin Hasani, Jennifer A. Eckhoff, Paul Pak, Ozanan R. Meireles, Guy Rosman, Yutong Ban, Daniela Rus
Download Paper | Download Slides
Teaching
Teaching Assistant
ECE2810J Advanced Data Structures and Algorithms, Shanghai Jiao Tong University, 2025
Teaching Assistant for ECE2810J: Held office hours and recitation sessions, and assisted with grading homework and exams.
Teaching Assistant
ECE2800J Programming and Elem. Data Structure, Shanghai Jiao Tong University, 2025
Teaching Assistant for ECE2800J: Held office hours and recitation sessions, and assisted with grading homework and exams.
Teaching Assistant
ENGL1000J Academic Writing I, Shanghai Jiao Tong University, 2024
Teaching Assistant for ENGL1000J: Held office hours to assist students in revising and improving their course papers.
Academic Advisor
Advisor at UMJI Advising Center, Shanghai Jiao Tong University, 2024
Academic Advisor for undergraduate students: Provided guidance on academic planning, course selection, and career development.